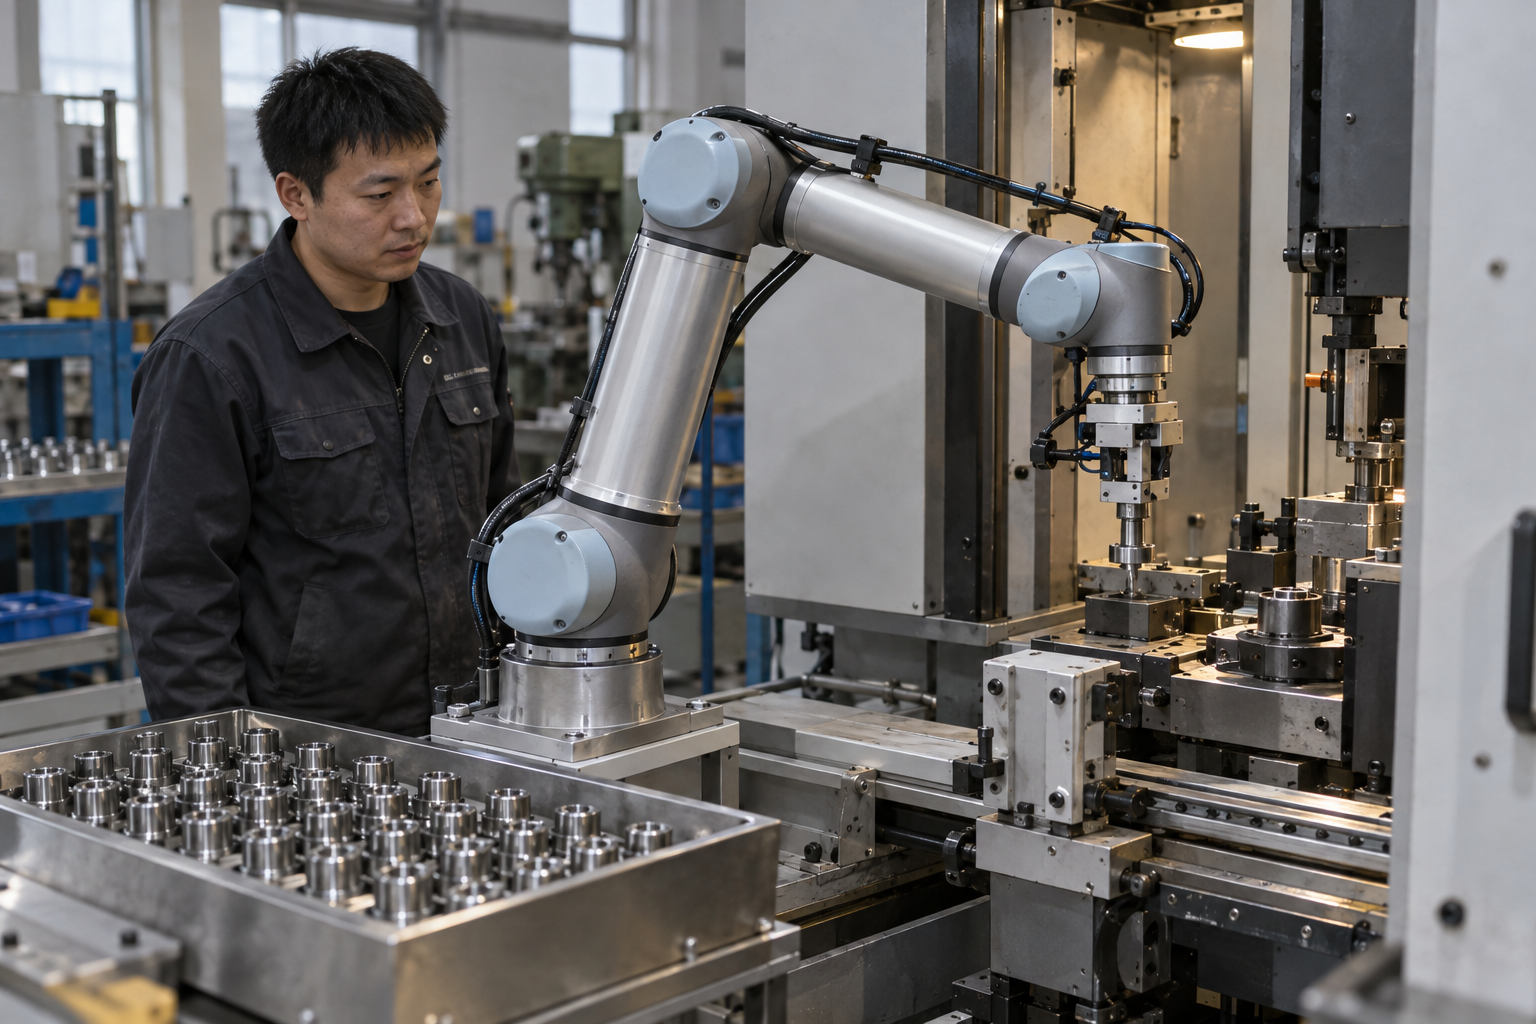
Rotary joint
Bearings, reducers, servo motors and locating parts form the support and output structure of a joint.
Robot-related mechanisms make limited space, load support, output flanges, backlash and linear positioning interdependent. A component list is most useful when arranged by motion axis and actual interface.
Connected families are organized by position in the mechanism. Final models and suitability follow the actual equipment requirements.
Bearings, reducers, servo motors and locating parts form the support and output structure of a joint.
Guides, screws, couplings and the drive end are matched by usable travel, installed height and shaft-end dimensions.
Compact guidance, timing transmission or gearing is combined to suit load, envelope and direction of motion.
Brand, model, drawing revision and inspection needs remain attached to each item as mating interfaces are reviewed together.
| Axis location | Component references, quantities and assembly orientation are identified for each axis. |
|---|---|
| Space and connection | Joint diameter, flange, output shaft, holes and cable clearance are reviewed together. |
| Load and precision | Radial and axial load, speed, backlash and repeatability belong to the relevant axis. |
| Existing-machine replacement | Original brand and full model remain visible; alternatives depend on interfaces and approved scope. |
Every linked component belongs to the nine-family ZOFANG portfolio.
ZOFANG coordinates transmission parts from different sources by machine position and requirement. Each part retains its own brand, full model, drawing and supply terms for confirmation.
Equipment settings may share product families while operating conditions and interfaces differ.
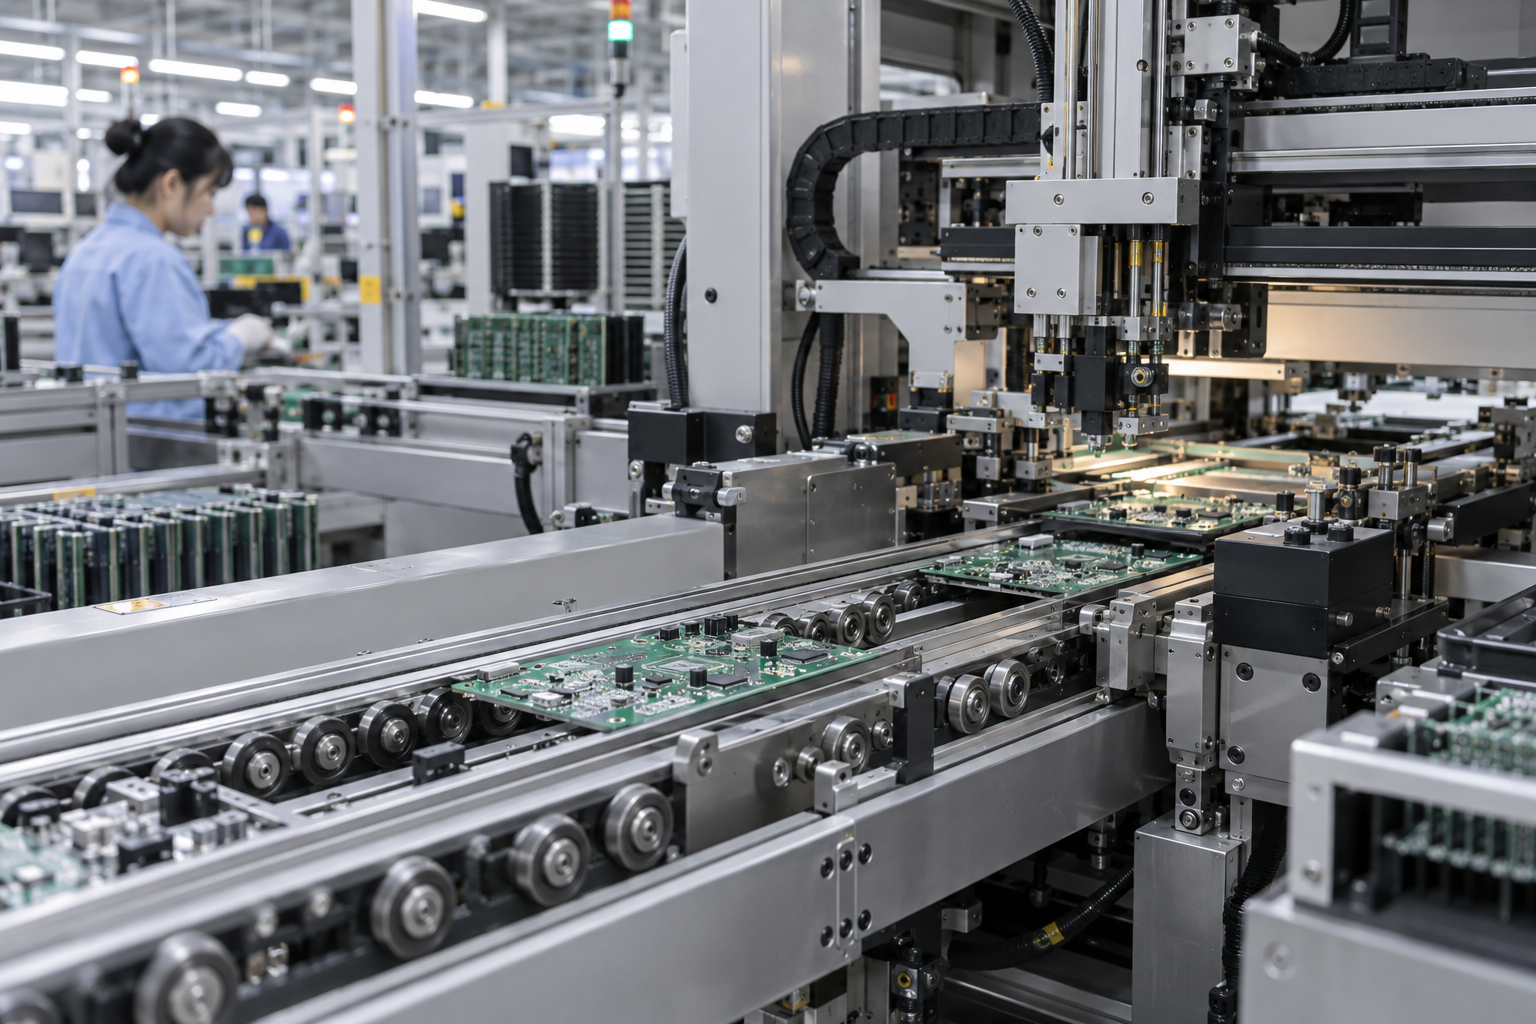
Transmission relationships in inspection, transfer and precision positioning.
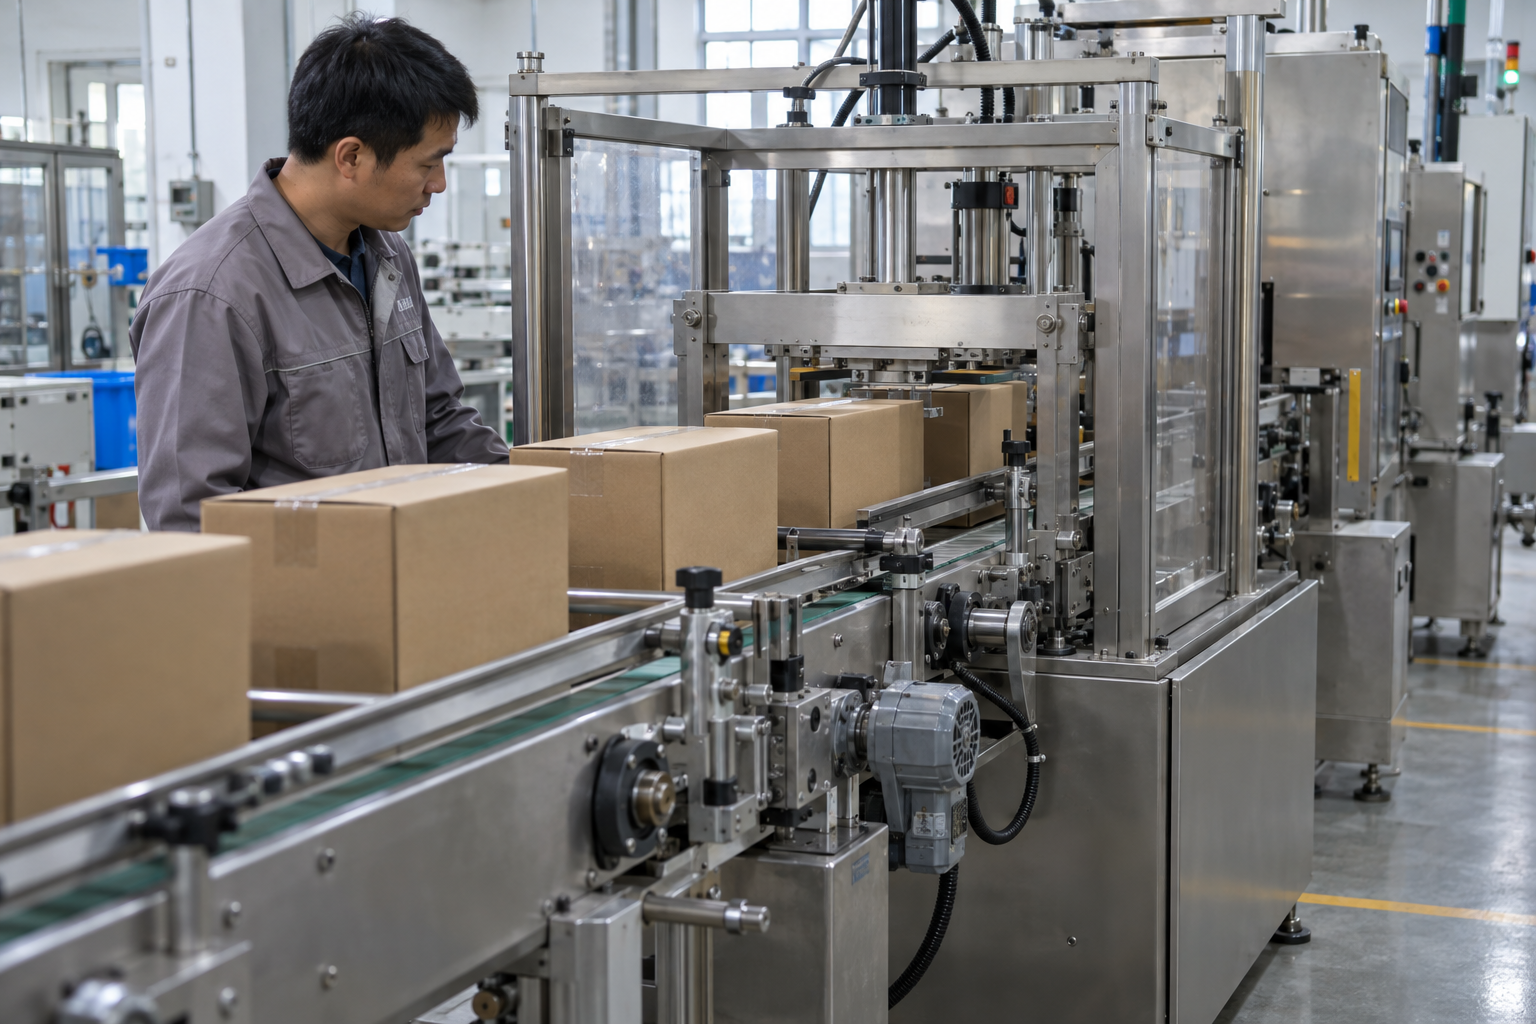
Parts for continuous running, indexing and format change.
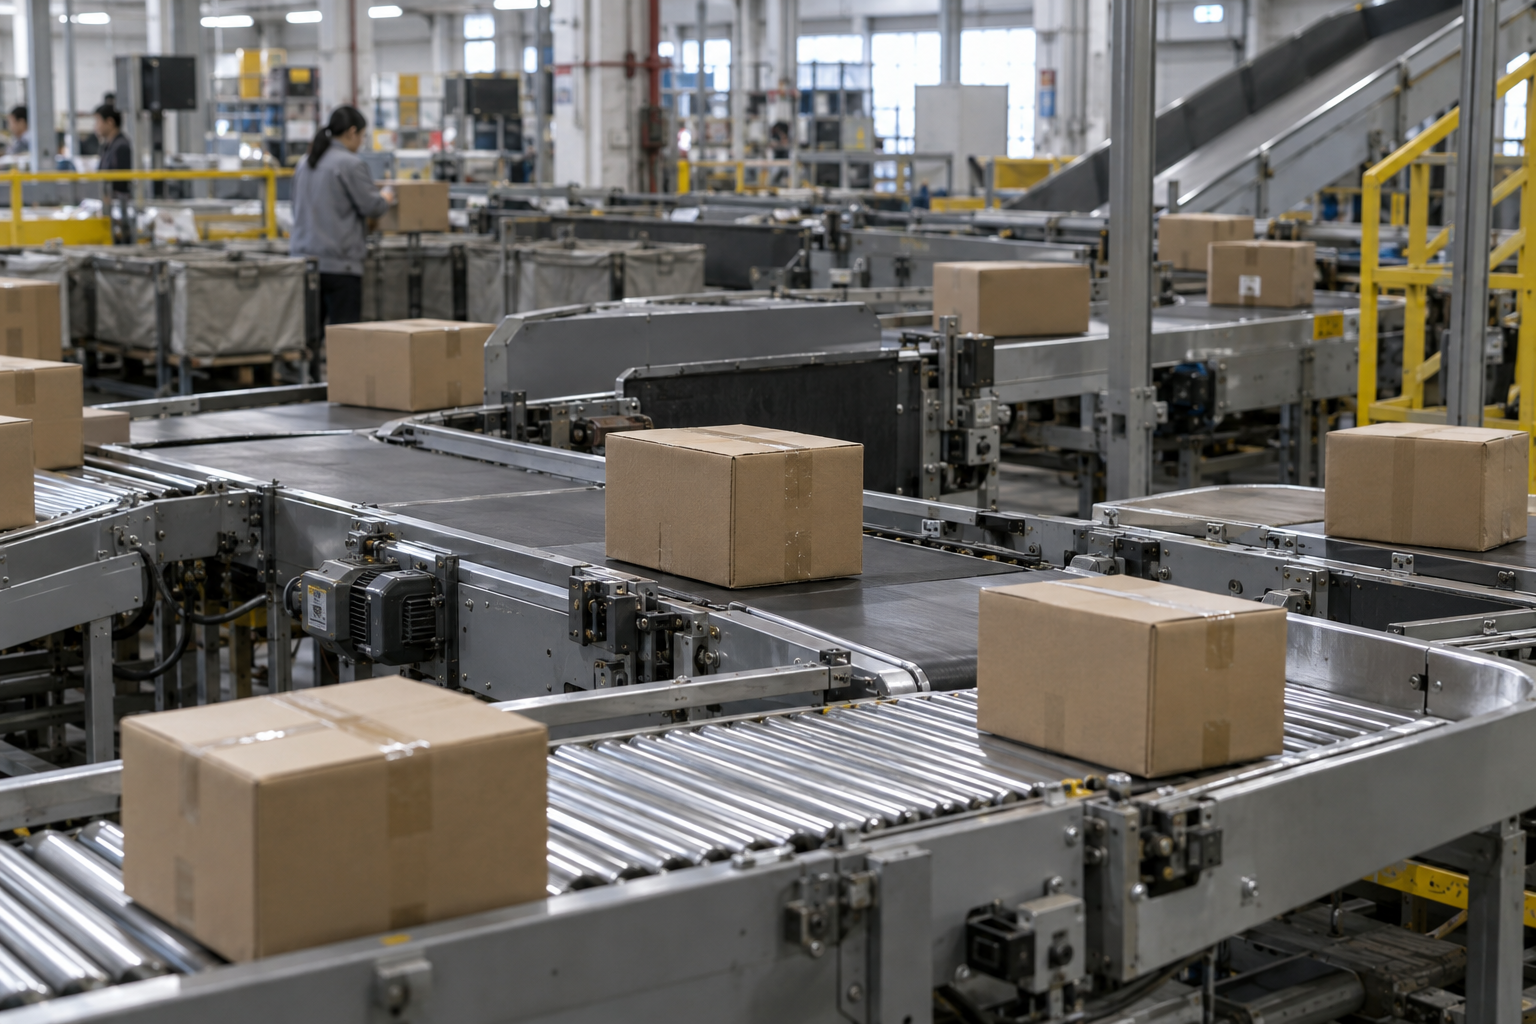
Continuous-running parts for rollers, conveyors and sorting.